 Portfolio
Two-stage clustering for improved indoor positioning accuracy
Published in Automation in Construction, 2023
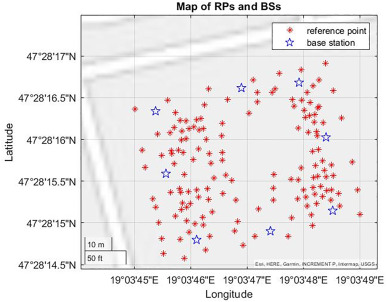
This paper proposes TSCA, a two-stage clustering-based indoor positioning method for complex indoor fingerprint datasets. It first uses the Group Matching Method to divide RSRP data into meaningful groups, then applies KNN-based positioning within the selected group to improve accuracy.
Citation
Lin, H., Purmehdi, H., Fei, X., Zhao, Y., Isac, A., Louafi, H., & Peng, W. (2023). Automation in Construction.